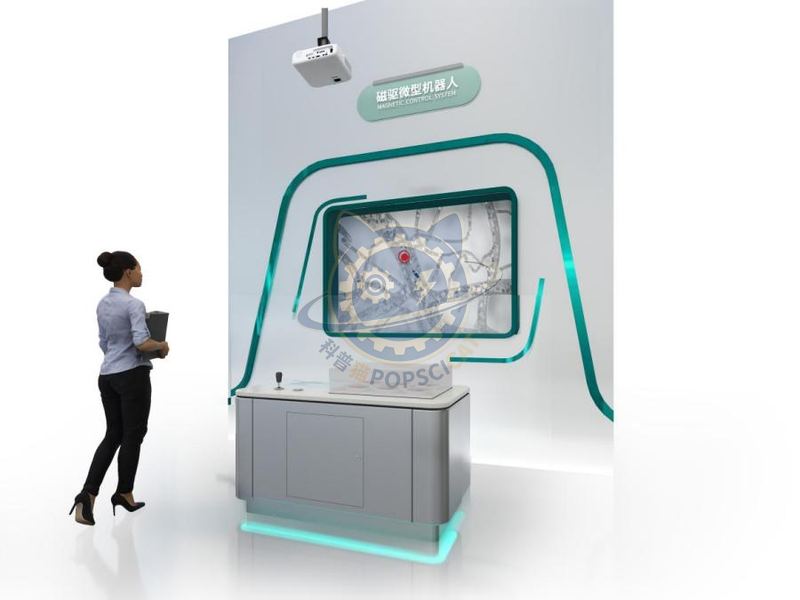
Magnetic driven micro robot is a type of micro device that utilizes magnetic fields for wireless driving.
| Category | Life Science & Health |
|---|---|
| Standard size | Custom size |
| Supply | Single unit or batch · OEM to your drawing |
| Lead time | Standard 4–8 weeks after deposit (confirmed per contract) |
| Warranty | 1 year, structure and control |
| Documents | Specification sheet · control diagram · spare-part list |
A standard catalogue model: the dimensions, control package and finish are fixed, which is what keeps the price and the lead time predictable. Size, colour and interface language can be adapted without a new design cycle.
Standard models from this range are also listed in our online store, priced in USD — see the price yourself ↗
Magnetic driven micro robot is a type of micro device that utilizes magnetic fields for wireless driving. This type of robot is usually compact in size and can enter the human body or other narrow spaces to complete complex tasks. Through the control of external magnetic fields, magnetic driven micro robots can achieve operations such as movement, grasping, and transportation. In the medical field, they demonstrate enormous potential for applications such as gastric examination and treatment, targeted drug delivery, minimally invasive surgery, and more. Magnetic driven micro robots, with their precise control and wireless drive characteristics, have brought new breakthroughs to the development of medical technology.
The unit is designed for unsupervised public use: controls are recessed or shielded, moving parts are enclosed, and the interface is operable by a child of about six with no instruction. Where a screen is used, the language can be switched without changing the hardware, and the content can be replaced on site.
In the medical field, magnetic micro robots driven wirelessly by low-intensity magnetic fields have shown great application prospects. These robots can move in narrow spaces for medical scenarios and complete complex tasks such as targeted drug delivery, micro operations, minimally invasive surgeries, etc. However, the practical application of magnetic microrobots also faces some challenges. One of the challenges is how to use a movable magnetic drive system to generate stable and efficient dynamic magnetic fields in human scale space, while avoiding potential collision safety issues between the magnetic drive system and the human body or other medical devices.
Every unit leaves the factory after a running test: mechanisms cycled, electronics burned in, edges dressed, fixings torqued and marked. Wear parts — bearings, sliders, lamps, belts, touch panels — are modular and listed on the spare-part sheet, so a venue technician can replace them without returning the exhibit. Crating is plywood with foam blocking; the loading plan and packing list travel with the shipment.
Other models from the Life Science & Health line, all held to the same specification and the same control package.

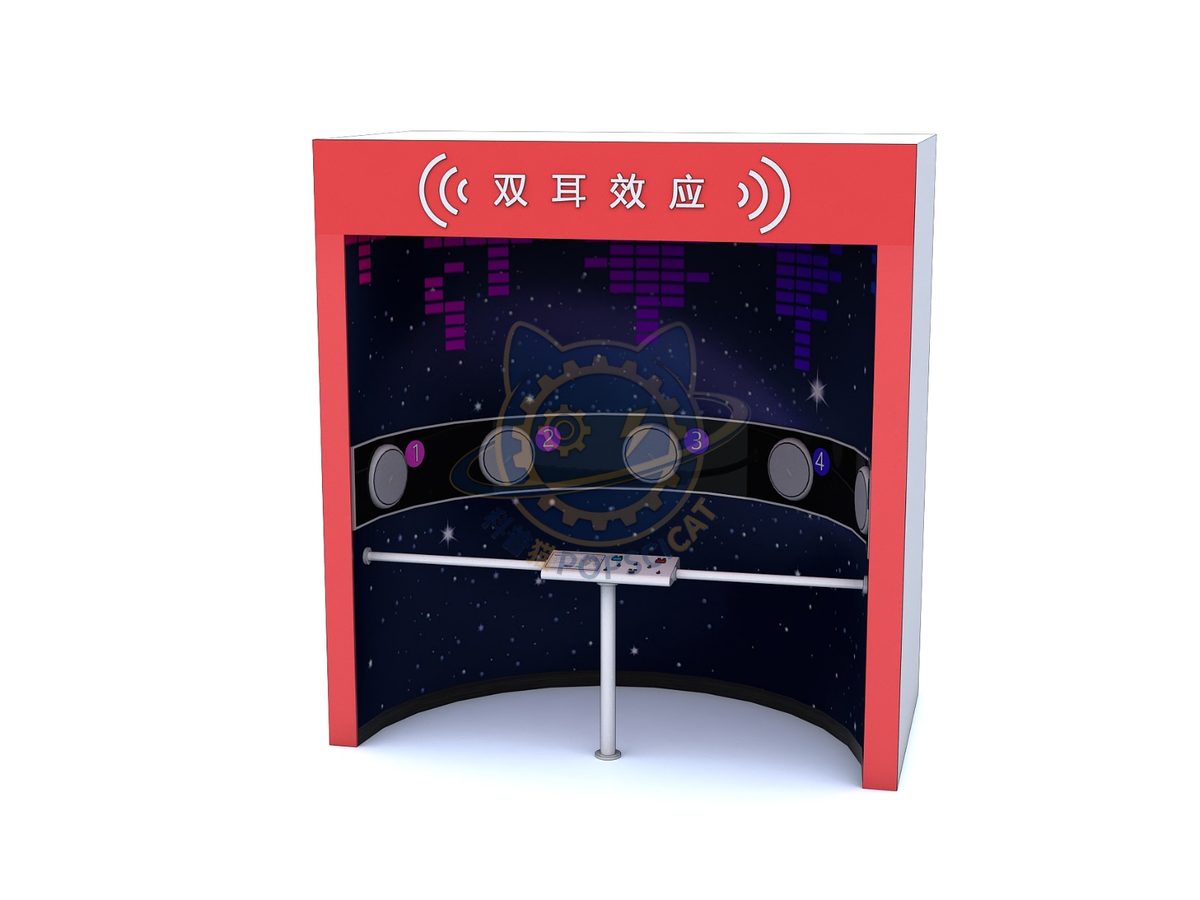
Sound reaches two ears at different times; visitors point to the source.

An adjustable lens projects a real image onto a retina screen.

Projected anatomy on a body-sized screen layer by layer.

Contract a model biceps and watch the tendon pull the forearm.
Attach a theme outline, a floor plan, or nothing at all — a photo of the space is enough to start. Quotations are issued against a real exhibit list, not per-square-metre guesses.
Scan to add us